


Introduction
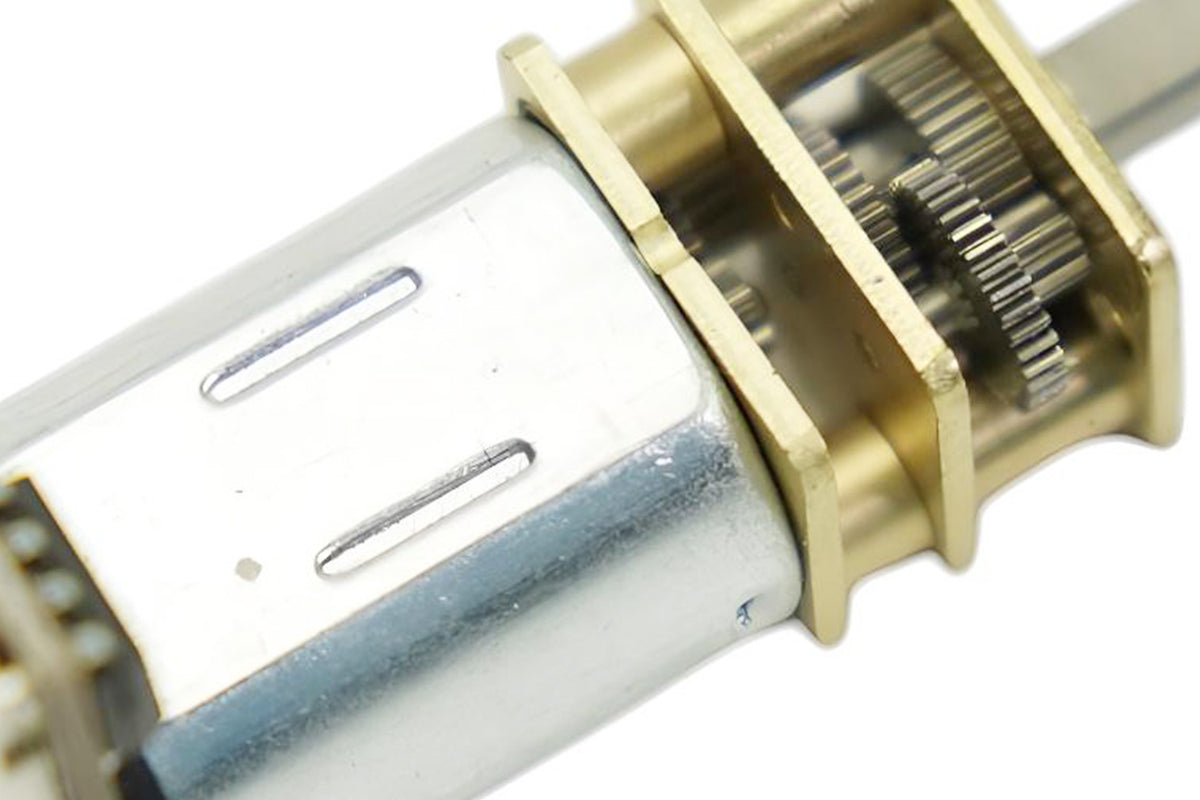
DC Micro Metal Gear Motor w/Driver - 30:1, 50:1, 75:1, 150:1, integrates a compact brushed DC motor, metal gearbox, and onboard driver circuit into a single easy‑to‑control motion component for rapid prototyping. Traditional DC motors normally require an external H‑bridge and additional wiring before connection to development boards such as Arduino. This gravity‑interface geared actuator simplifies the process by embedding the control electronics directly inside the motor module. A single signal line enables bidirectional rotation and speed control, allowing robotics builders, automation prototypes, and educational projects to implement reliable motion control without designing a separate motor driver stage.
Note: The embedded control chip consumes a small portion of the input voltage, so the effective voltage delivered to the motor is slightly reduced. Motor speed may therefore be marginally lower than the rated motor speed.
Single‑Signal Motor Control via Gravity Interface
This gravity‑series actuator uses a standardized 3‑pin interface that combines power, ground, and signal lines for simplified wiring. Forward rotation, reverse rotation, and speed adjustment are controlled through PWM or PPM signals from a microcontroller. Such streamlined control removes the need for external H‑bridge modules or complex wiring, reducing setup time for robotics prototypes and motion experiments. Compatibility with common servo‑style signals enables immediate integration with many embedded controllers while maintaining the simplicity expected from plug‑and‑play Gravity ecosystem modules.
Hybrid Behavior Between DC Motor and Continuous Servo
This micro geared drive combines characteristics of a standard DC motor with continuous‑rotation servo control logic. Pulse width signals determine direction and rotational speed, enabling smooth forward or reverse movement with precise command ranges. An expanded stop pulse range improves neutral stability, preventing unintended movement during signal transitions. Such servo‑style control makes the compact gearbox motor particularly useful in robotics wheels, small mechanical actuators, and motion demonstrations where intuitive PWM control is preferred over raw voltage driving.
Low Standby Current for Efficient Embedded Systems
Integrated driver electronics maintain extremely low standby consumption when no control signal is present. Static current remains below 1 mA without PWM input, reducing wasted energy in battery‑powered robots and portable embedded devices. This efficient operating profile allows the small metal gearmotor module to remain connected during idle periods without significant power drain, making the component suitable for long‑running automation projects, mobile robots, and compact smart mechanisms where power management matters.

This compact motion control module fits a wide range of robotics and educational builds, including mobile robot wheels, mechanical linkages, miniature automation systems, and interactive prototypes. Servo‑style PWM control and integrated driver electronics make the geared motor well suited for rapid experimentation in robotics labs, maker workshops, and STEM Education environments where reliable motion components accelerate prototype development.
Features
- Integrated driver circuit removes the need for an external H‑bridge motor controller
- Gravity 3‑pin interface for quick plug‑and‑play wiring
- PWM/PPM signal control enabling forward, reverse, and speed adjustment
- Hybrid behavior combining DC motor power with continuous servo control logic
- Expanded stop pulse range for improved neutral stability
- Low standby current below 1mA when no control signal is present
- Compact metal gearbox suitable for robotics and embedded motion systems
Applications
- Small mobile robots and robotic wheel drives
- Educational robotics and STEM Education experiments
- DIY automation mechanisms and moving prototypes
- Interactive installations and kinetic projects
- Compact actuator systems for embedded hardware builds
Specification 30:1
- Operating voltage: 3.5V - 8V
- Reduction ratio: 30:1
- No load current: 40mA@6V (approx)
- Static current: < 1mA (no PWM control signal input)
- Interface: Gravity 3-Pin
- PPM signal resolution: 1us
- PPM signal pulse width range: 500us-2500us
- Clockwise pulse width range: 500us-1400us (500us speed maximum)
- Stop pulse width range: 1400us-1600us
- Anticlockwise pulse width range: 1600us-2500us (2500us speed maximum)
- PWM frequency: 500 Hz.
Specification 50:1
- Operating voltage: 3.5V - 8V
- Reduction ratio: 50:1
- No load current: 40mA@6V (approx)
- Static current: < 1mA (no PWM control signal input)
- Interface: Gravity 3-Pin
- PPM signal resolution: 1us
- PPM signal pulse width range: 500us-2500us
- Clockwise pulse width range: 500us-1400us (500us speed maximum)
- Stop pulse width range: 1400us-1600us
- Anticlockwise pulse width range: 1600us-2500us (2500us speed maximum)
- PWM frequency: 500 Hz.
Specification 75:1
- Operating voltage: 3.5V - 8V
- Reduction ratio: 75:1
- No load current: 40mA@6V (approx)
- Static current: < 1mA (no PWM control signal input)
- Interface: Gravity 3-Pin
- PPM signal resolution: 1us
- PPM signal pulse width range: 500us-2500us
- Clockwise pulse width range: 500us-1300us (500us speed maximum)
- Stop pulse width range: 1400us-1600us
- Anticlockwise pulse width range: 1700us-2500us (2500us speed maximum)
- PWM frequency: 500 Hz.
Specification 150:1
Power Parameters
Operating Voltage Range: 3V-6VRated Voltage: 6VNo-load Current: 50mA (under 6V)Static Current: <1mA (no PWM control signal input)Stall Current: 640mAMotor ParametersMotor Speed (Unreduced): 20,000 RPMGearbox Reduction Ratio: 150:1No-load Output Speed: 133 RPMStall Torque: 1.0 kg*cm
Control ParametersPPM Signal Resolution: 1μsPPM Signal Positive Pulse Width Range: 500μs-2500μsForward Pulse Width Range: 500μs-1400μs (maximum speed at 500μs)Stop Pulse Width Range: 1400μs-1600μsReverse Pulse Width Range: 1600μs-2500μs (maximum speed at 2500μs)PWM Drive Frequency: 500 Hz
Other ParametersWeight: 10gDimensions: L40mm × W12mm × H20mm
Dimension (150:1)
